Forenly AI Lab
The fridge drawer twin
The robot shuts the drawer by hand; a soft-close spring takes the last stretch.
We rebuild real Unitree G1 jobs in MuJoCo and rerun them with the robot balancing on its own. Four of eight jobs pass, and every attempt stays published.
Each job starts from one real recording. We rebuild the place, rerun the job with the AMO and GR00T balance controllers, and keep every attempt. See what failed
The robot shuts the drawer by hand; a soft-close spring takes the last stretch.
Both bottles held by finger friction alone, the wrist 2.2 cm from the recording.
All of a 30 g cloth ends in the tray; grip points stay held while the hand is closed.
AMO and GR00T pass 6 of 6 runs, checked from the side.
In the crouch the wrist drifts 4 cm and knocks the cabbage over.
A rigid bundle gets pushed, not pinched.
The plate lay on top of the rack; a target box that was too tall called it a pass.
The dataset has no leg recording, so the job is parked.
What a pass means
A run passes only when the robot stays on its feet, the object ends where the real one did, and every fit we made is written next to the result.
Pick a job, rerun it in MuJoCo with our G1 model, and post the run with its fits. Good runs join this log under your name.
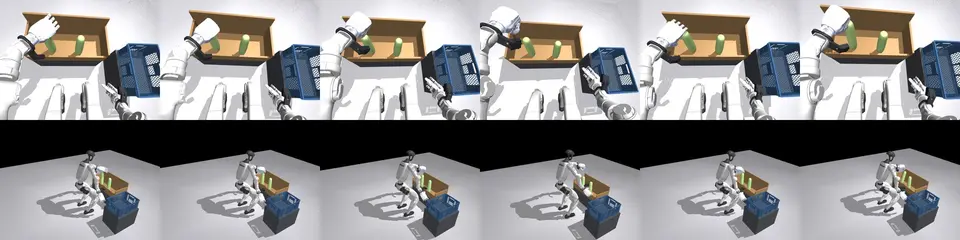
Get the wrist within 2 cm in the crouch so the cabbage is grasped.
Not started; builds on the cloth method that passed the tray job.
Not started; a large cloth and the hardest job in the log.
Parked until someone finds a pour recording with the legs in it.
Plus 9.5 dB image quality on our own 3-camera capture.
A measured model of a real kitchen, ready for training.
62.0% measured against 65.4% published, over 500 episodes.
What a widely shared lab video shows and what it does not.