 Forenly AI Lab
Pipetting robot clip study
A claim of 69% success over three tasks travelled with a twenty-second clip that shows one of them, once. Here is what the clip proves and what our runs show.
What the pipetting clip shows in twenty seconds.
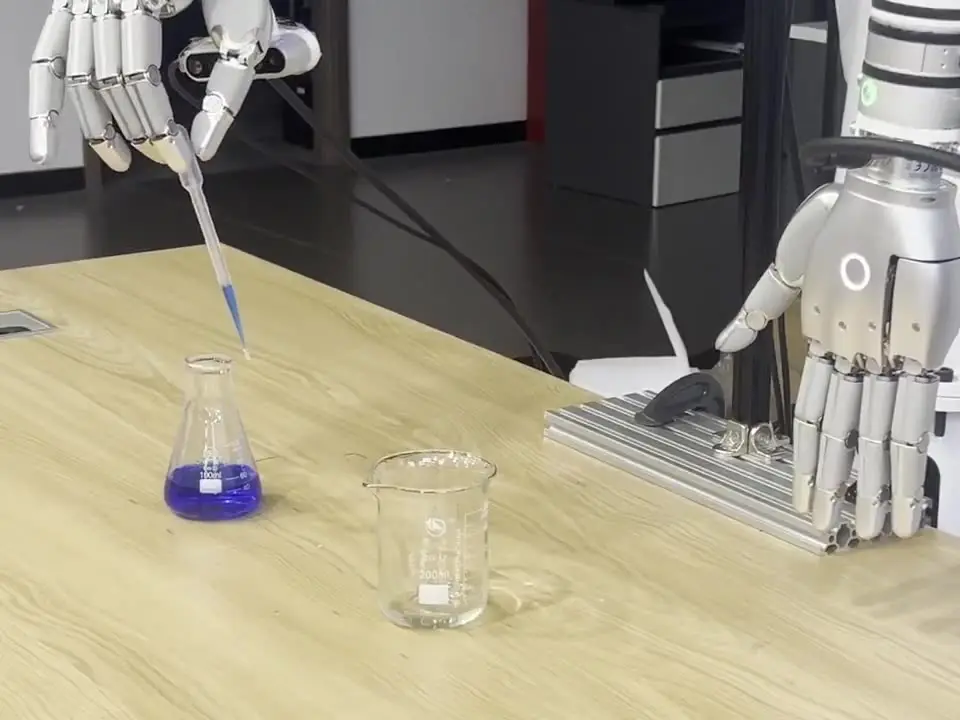
A fixed camera on a lab bench and two five-finger hands; only one moves, so the task as filmed is one-handed. No arm, torso or head is visible.
- 2 s
- The hand hovers above the flask
- 8 s
- The pipette is lifted clear
- 13 s
- The tip is in the beaker
- 18 s
- Released across the rim
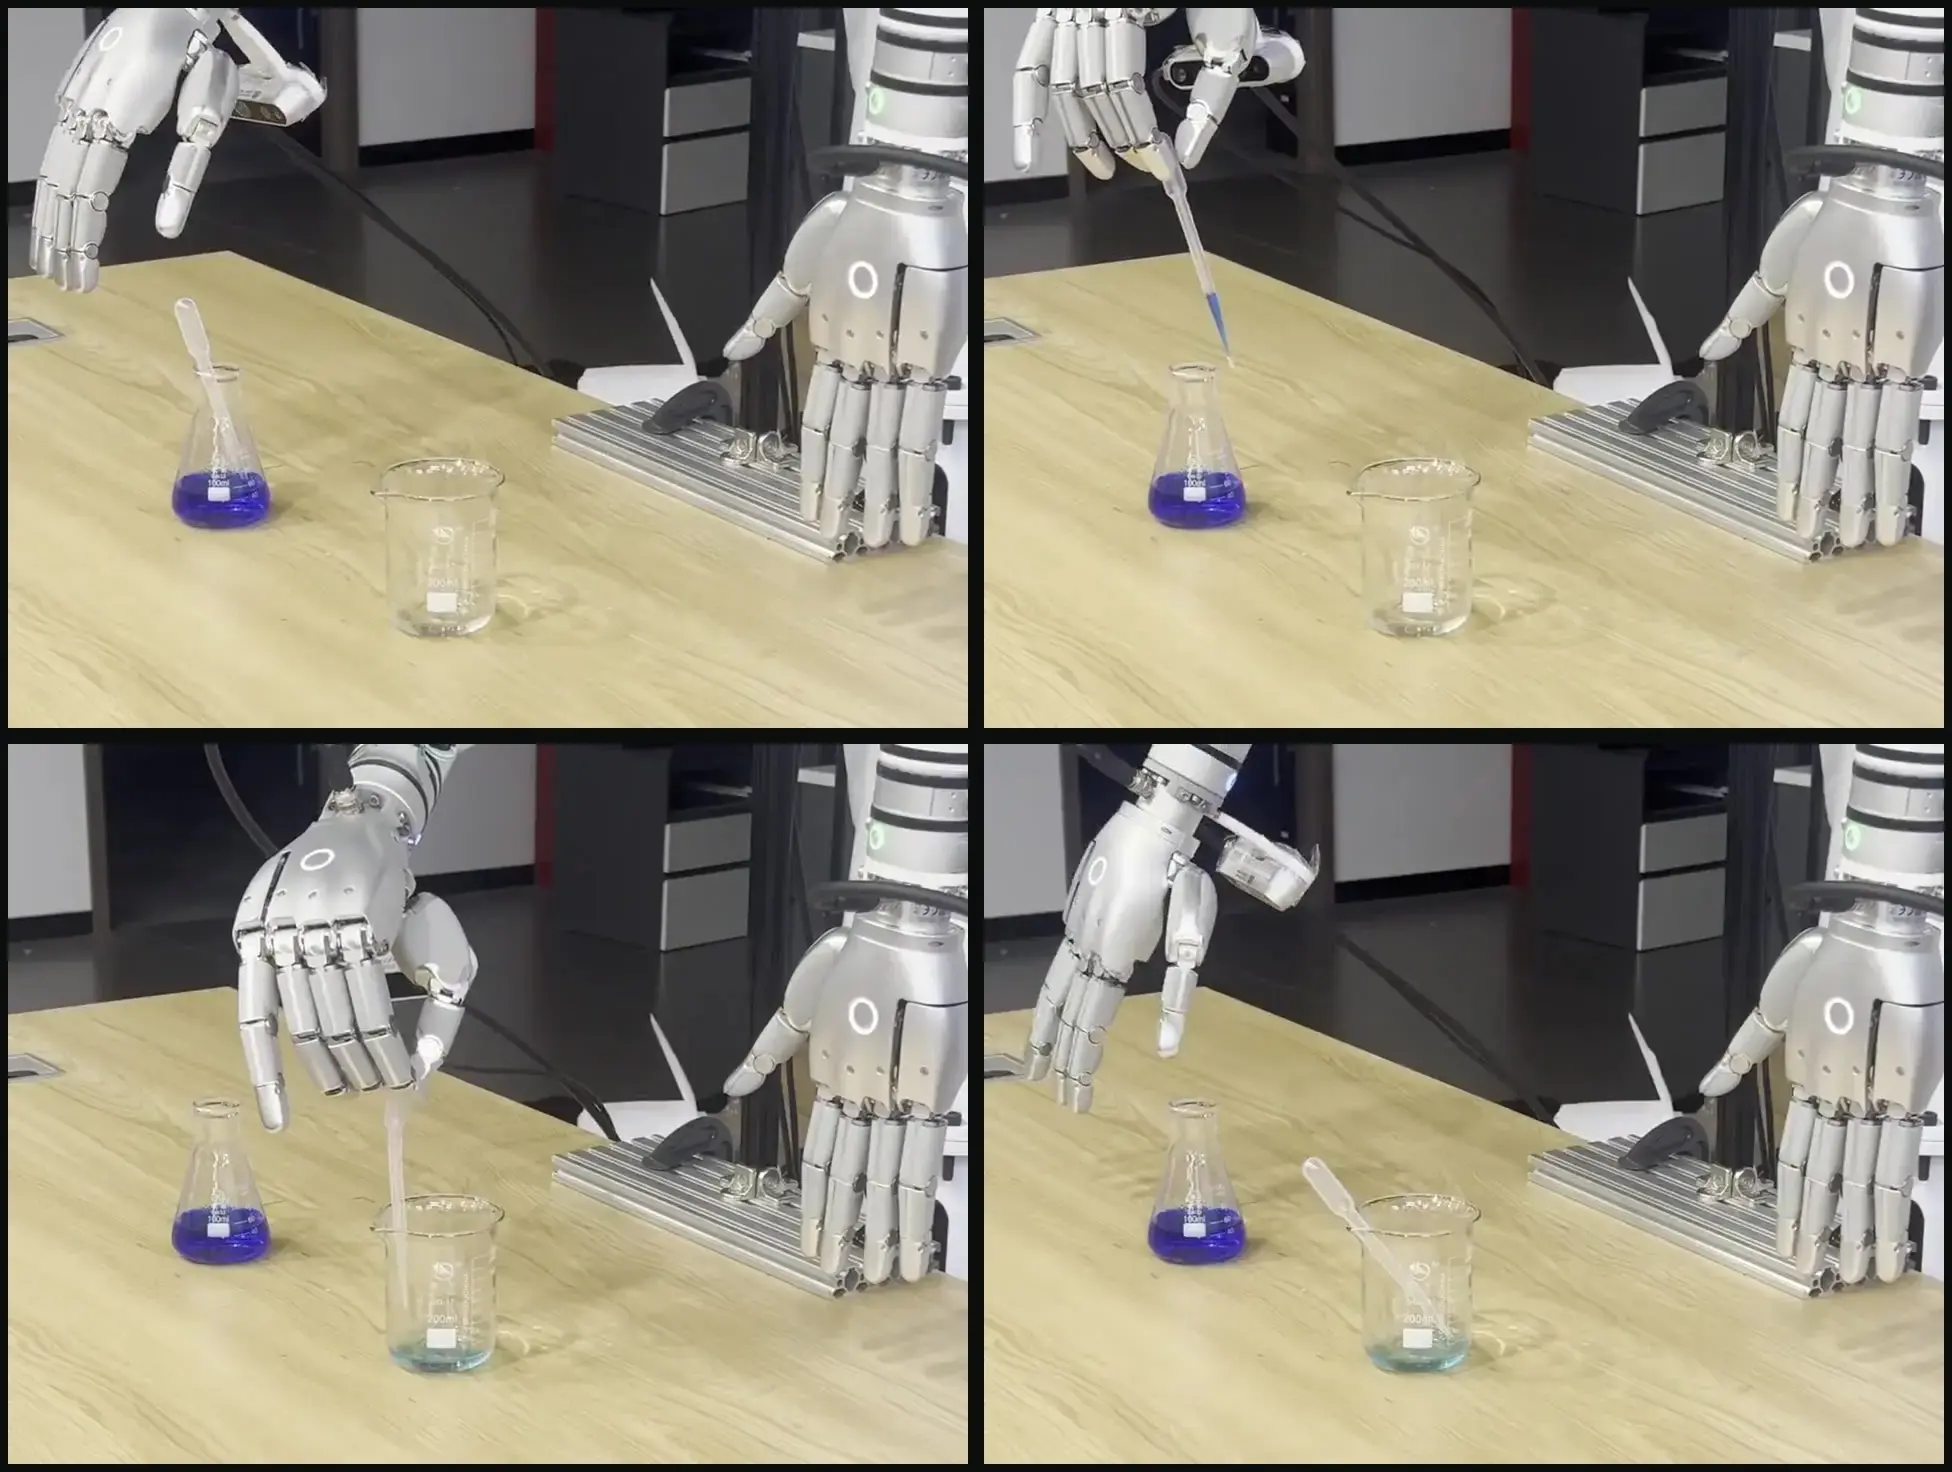
Six things the pipetting clip does not contain.
None of this makes the claim false. It makes it unverified: a clean single take is a demonstration, and 69% is a measurement.
The cited preprint is not linked, and two searches, by name and by the three tasks, found nothing matching.
Three blocks to reproducing the pipetting method.
- 1 · No touch channel
Our G1 and Inspire model has no per-fingertip touch signal, so a policy built on one can be imitated, not evaluated.
- 2 · No liquid in MuJoCo
Drawing up and dispensing have no match. Grasp, lift, carry and release can be measured, and we will not score them as the harder task.
- 3 · Resolved: no GPU on this host
The work moved to rented GPUs, checked with nvidia-smi inside the containers; π0 inference runs on an A10.
What has run on the AutoBio pipetting scene.
A published MuJoCo benchmark with a pipetting task already exists, AutoBio (ICLR 2026), so we ran that, unmodified, instead of scoring a private copy.
- The loop runs, the task does not
All fourteen joints move for thirty cycles, yet the free body moved 0.912 mm and the tip stayed 74.8 cm or more from the tube.
- Our own classifier was wrong first
It first counted the tube resting in its rack as contact; both of its errors flattered the result.
Where the claim stands
We still have no number on the 69% claim, and we will not dress nearby results up as an answer to it.