A humanoid that serves tea in a real café
A café in Türkiye asked for a robot waiter. We follow one chain from start to finish — the real place, its digital twin, training in simulation, and then the real robot on the real floor.
- Customer
- Café, Türkiye
- Robot
- Unitree G1 · dexterous hands
- Job
- Serve tea, collect glasses
- Started
- 20 Sep 2026
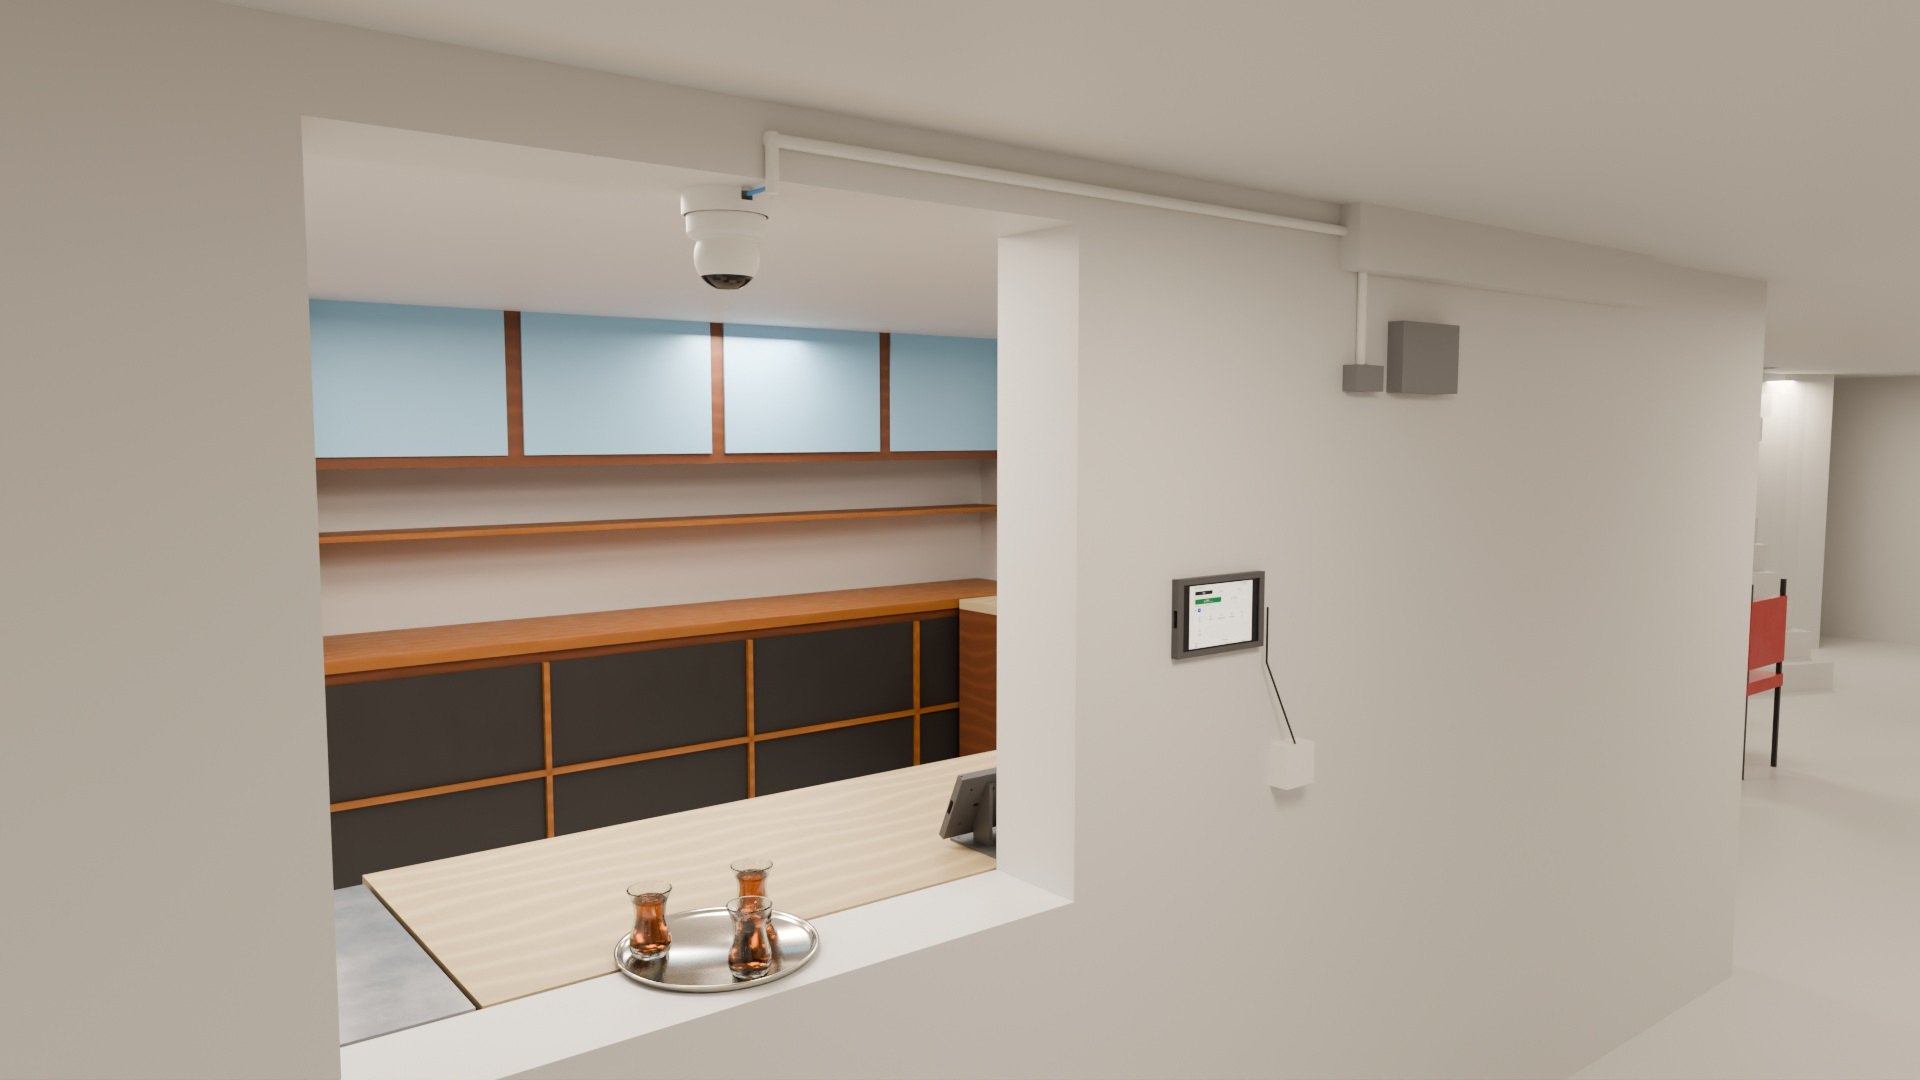 Digital twin · the serving window
Real
What the customer sent
Everything starts from the real place. The owner sent a walk-through filmed on a phone and a recording from the security camera above the counter.
The counter camera shows the job the robot has to learn, done by hand: full glasses go onto the tray and are carried to the tables.
Guests’ faces are kept out of these clips.
Real → Sim
The digital twin
From those videos the building, the ground-floor hall, the counter and the street outside were rebuilt to measured size — the serving window at the top of this page is the twin. Small markers on each table give the robot a fixed point to find its way by; the same markers go on the real tables.
Real next to twin
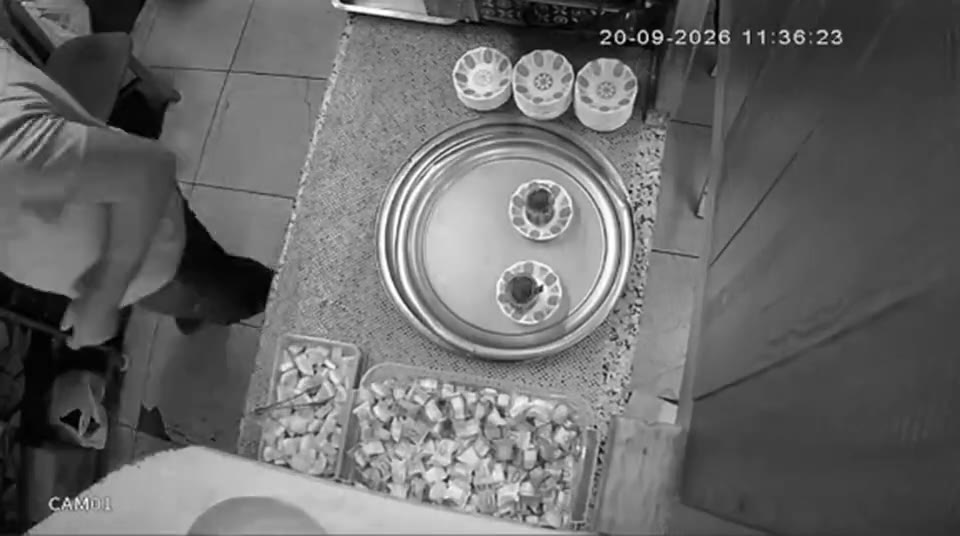 Real · the tray
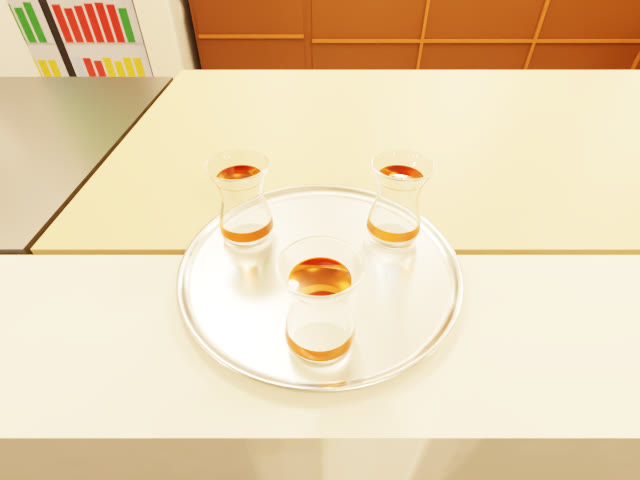 Twin · the tray
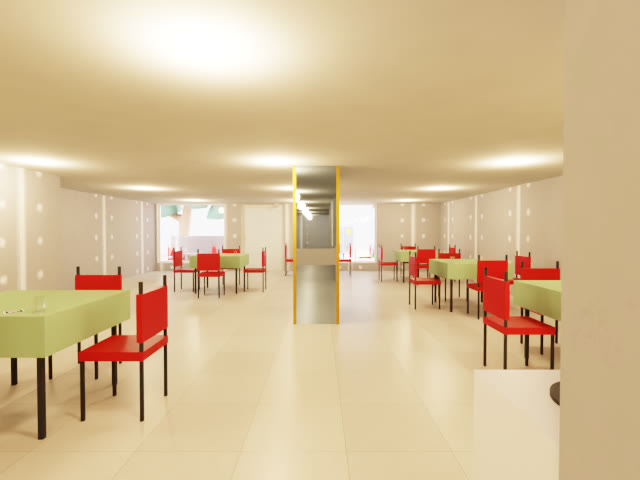 Twin · hall
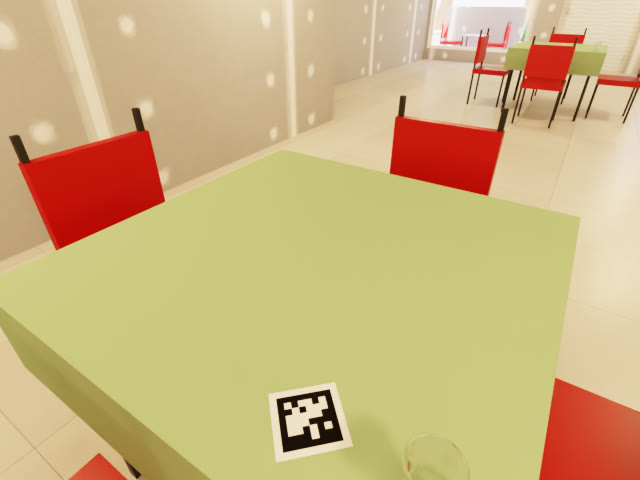 Twin · table marker
Sim
Learning the job
The tea maker keeps pouring — that part stays human. The robot does the walking: it picks up the glasses waiting on the tray, carries them to the right table, and on the way back collects the empty ones. Training runs in physics simulation inside the twin, so balance, grip and the weight of a full tray are the robot’s problem to solve, not an animator’s.
Sim → Real
On the real robot
The skill trained in the twin goes onto a real Unitree G1 and is checked on the real floor of the same café, against the same table markers.
This step has not happened yet. It will appear here, with footage, when it does.
The tea counter
Also at this café · the same twin, a second job
Before the robot arrives, the café gets something simpler: one camera above the tray counts every glass of tea that leaves the counter, and two tablets — one for the tea maker, one for the waiter — record everything else. At the end of the day the owner sees the sales on his phone.
The installation was designed inside the twin, so where the camera hangs, what it will see and where the cables run were settled before anyone picks up a drill. Nothing is installed yet.
An animation made in the twin, with Turkish captions as shown to the owner. The inset is the tray camera’s view: each glass is counted as it goes on and comes off the tray.
Installation plan
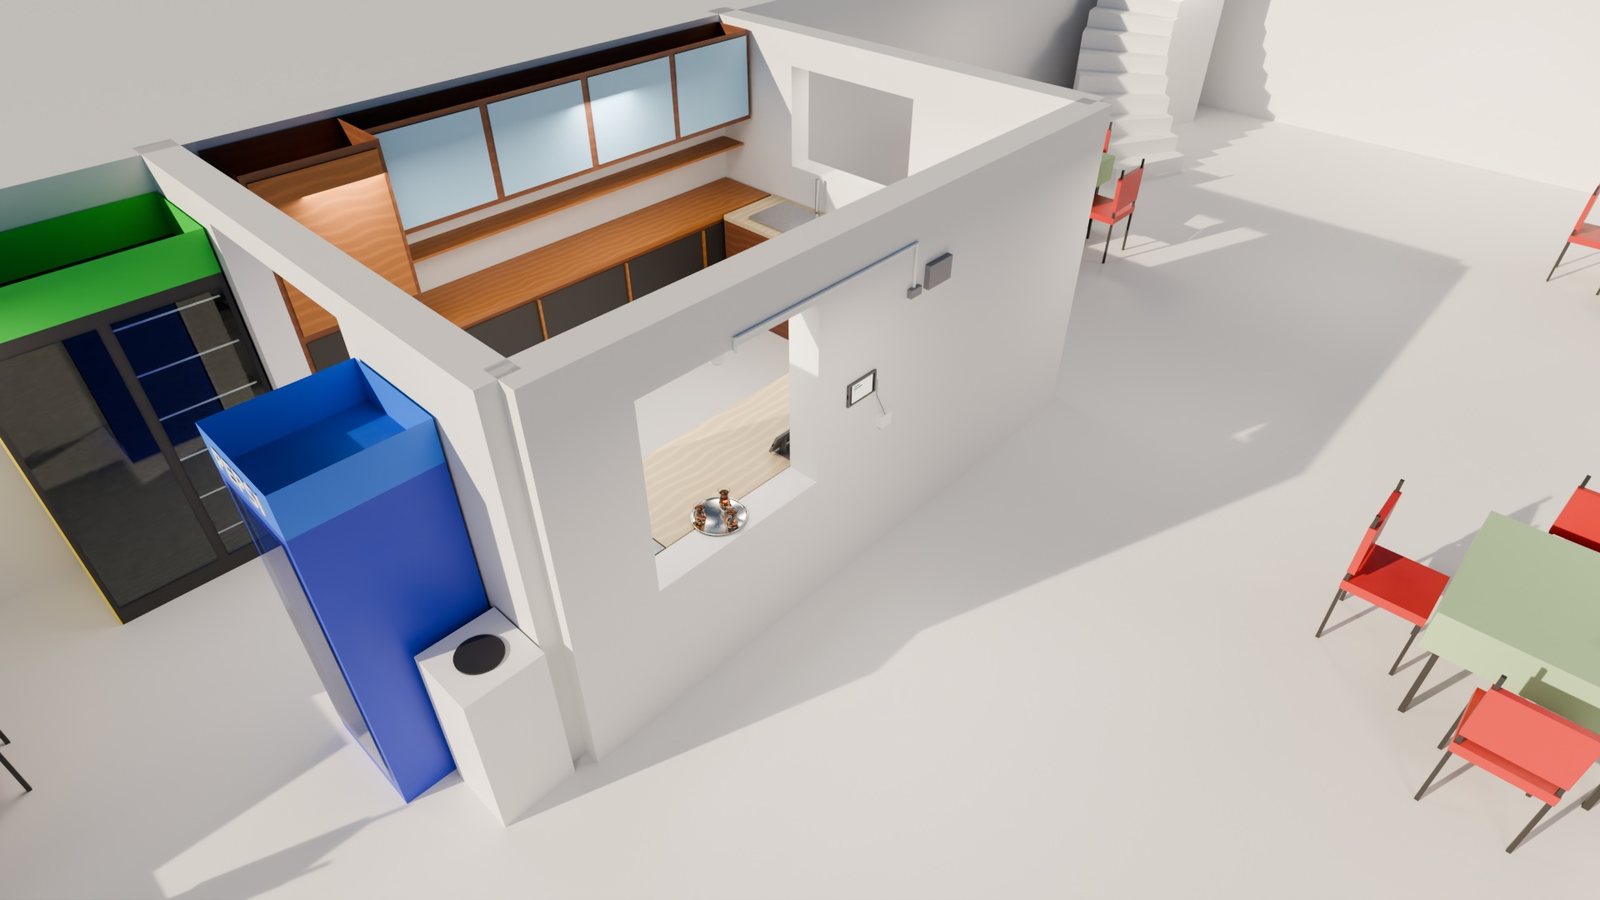 Plan · counter from above
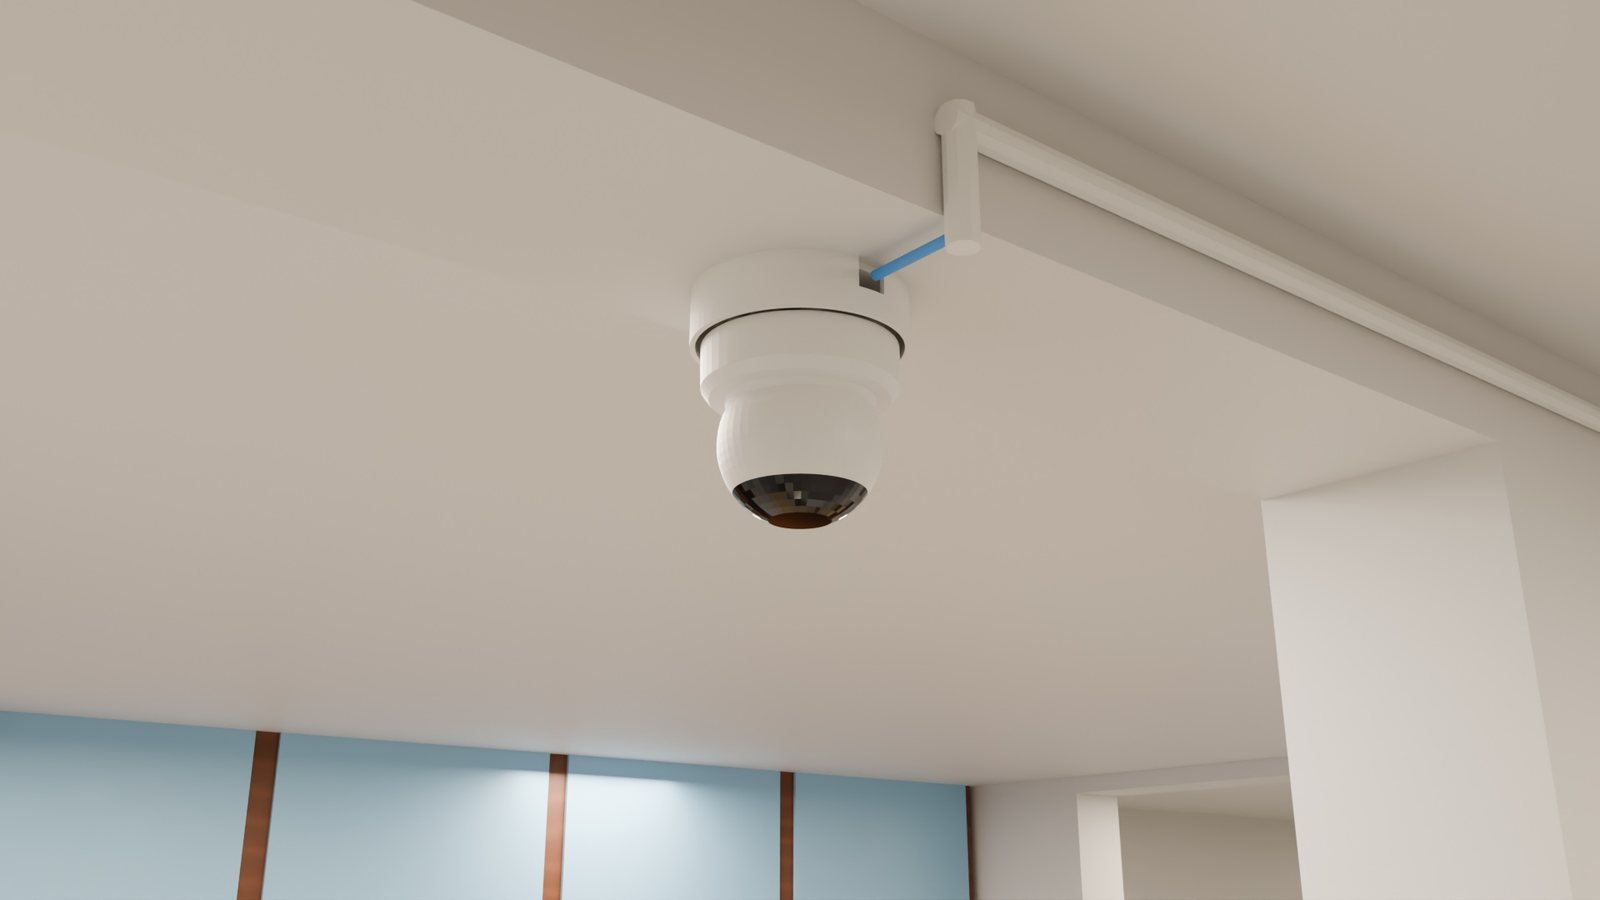 Plan · the camera
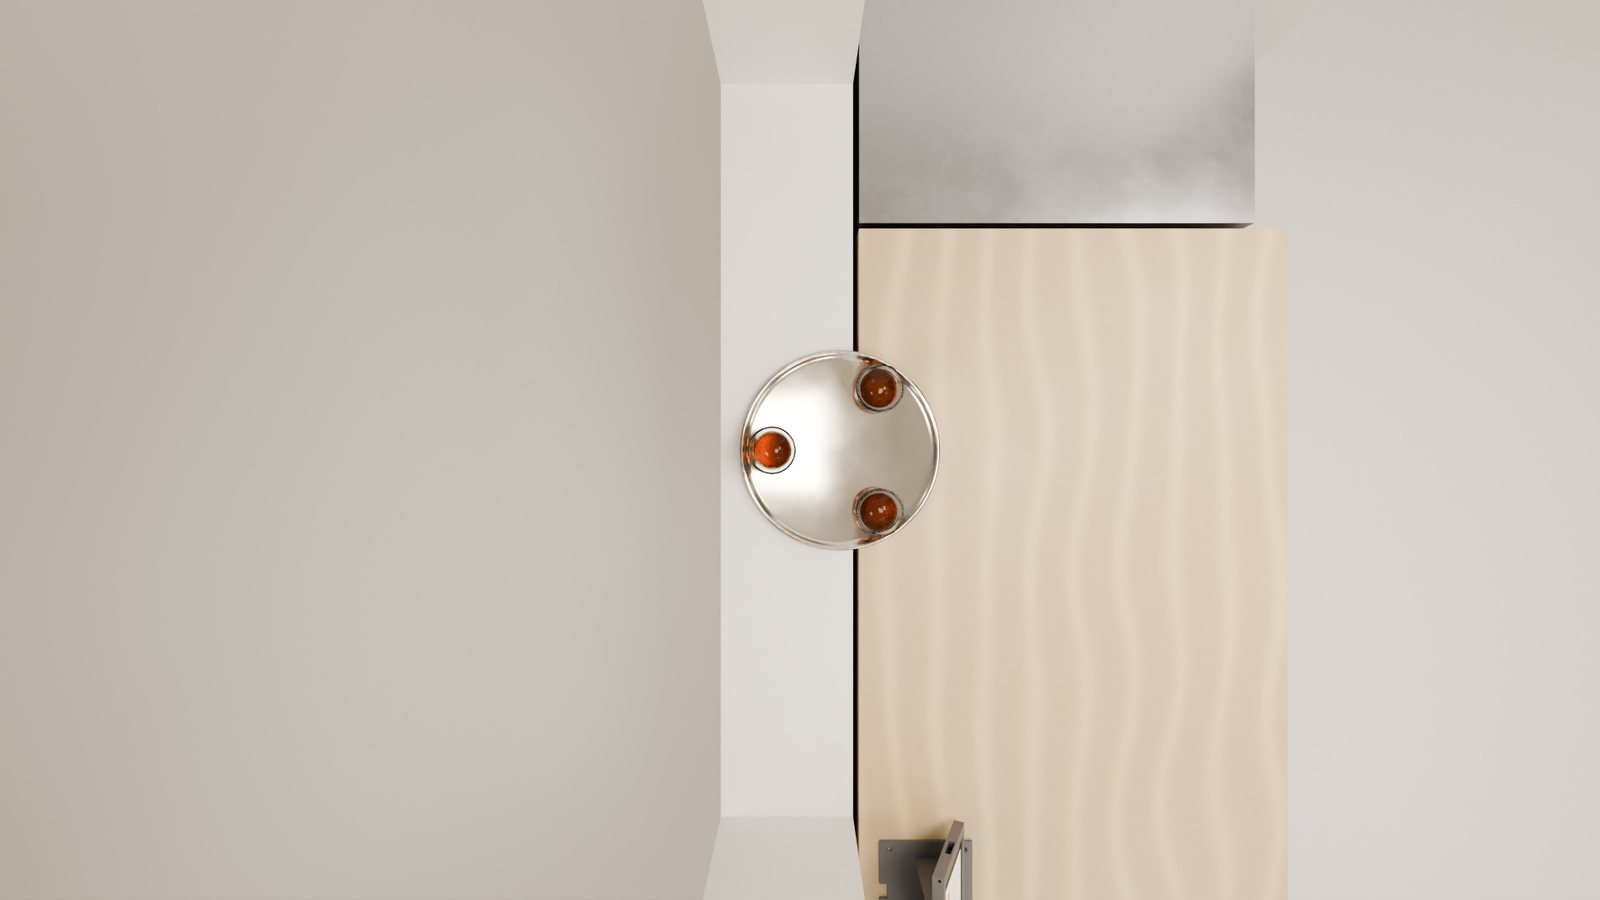 Plan · what the camera will see
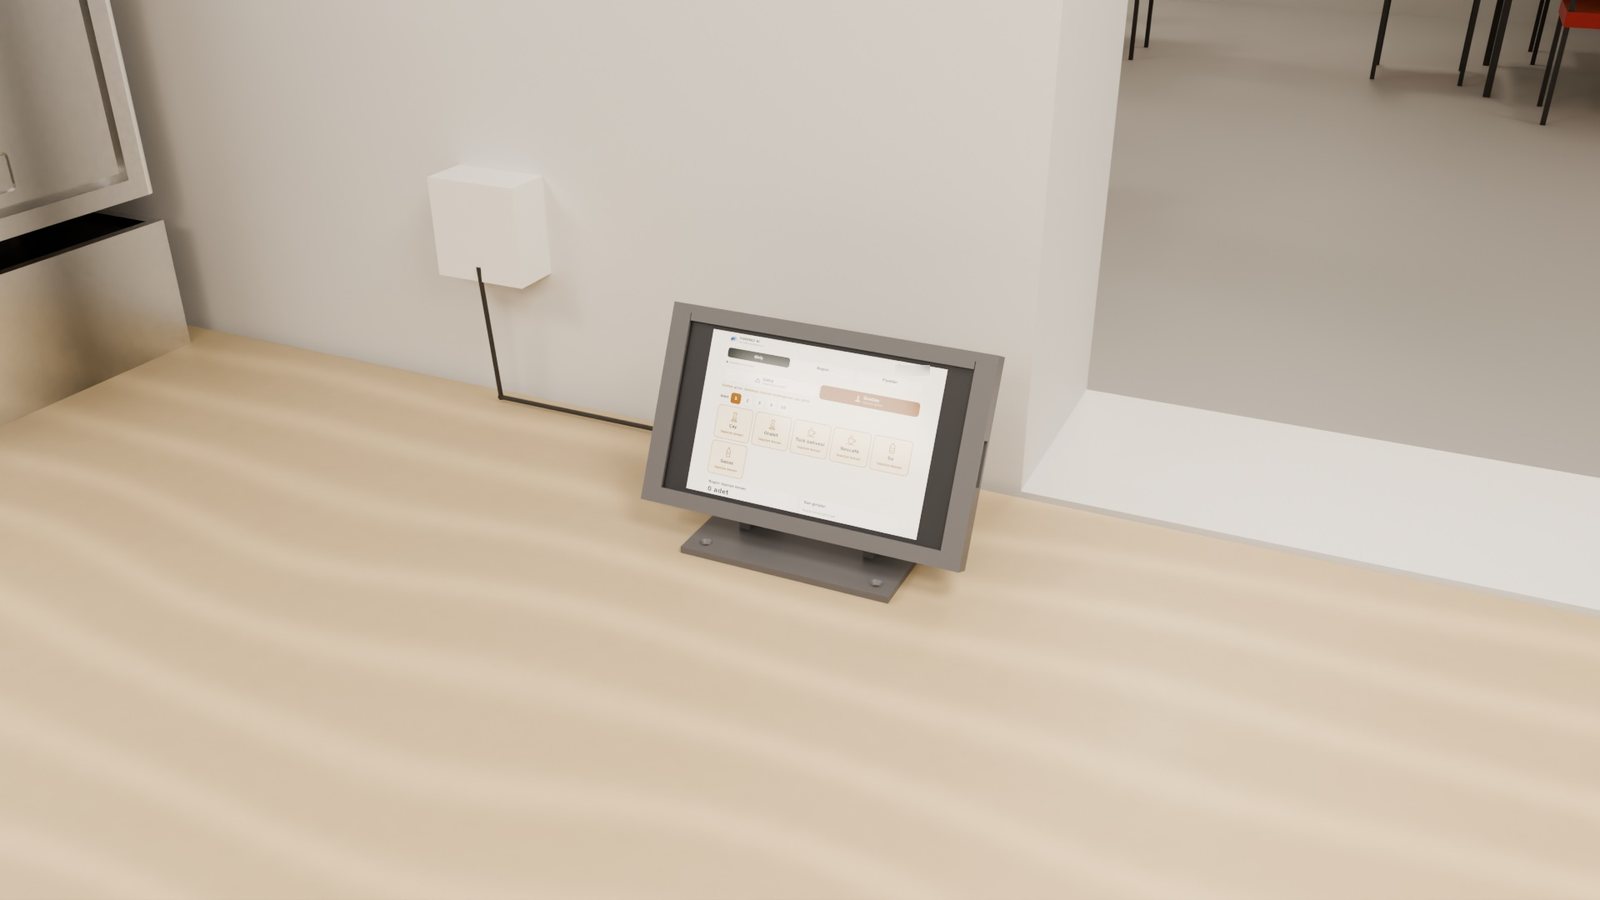 Plan · tea maker’s tablet
Project log
Newest first · updated 7 Oct 2026
- Tea counter
Tea counter: installation designed in the twin — one camera above the tray, two tablets, cable routes and mounting parts.
- Real → Sim
Twin walk-through rendered: from the street, through the hall, to the tea tray at the counter.
- Sim
Fine-tuning the robot policy (π0.5) on the recorded serving runs.
- Sim
Serving runs recorded in the twin with all three robot cameras.
- Real → Sim
Twin published for training: hall, counter and 13 table markers.
- Real → Sim
Building, hall and street rebuilt to measured size: ground floor, counter, upper hall.
- Real
Walk-through video of the venue received from the owner.
- Real
Counter camera recording: the tea round done by hand.
AI for Humanoids
Forenly AI turns real scenes into simulation where humanoids learn their skills — then transfers them onto the machine.